Force is the sense robots have been missing.
Enact is rethinking the robotic tech stack from model architectures and data pipelines down to the actuators and sensors that feed the model, to solve dexterity through whole-body force awareness.
Sensing inside the actuators.
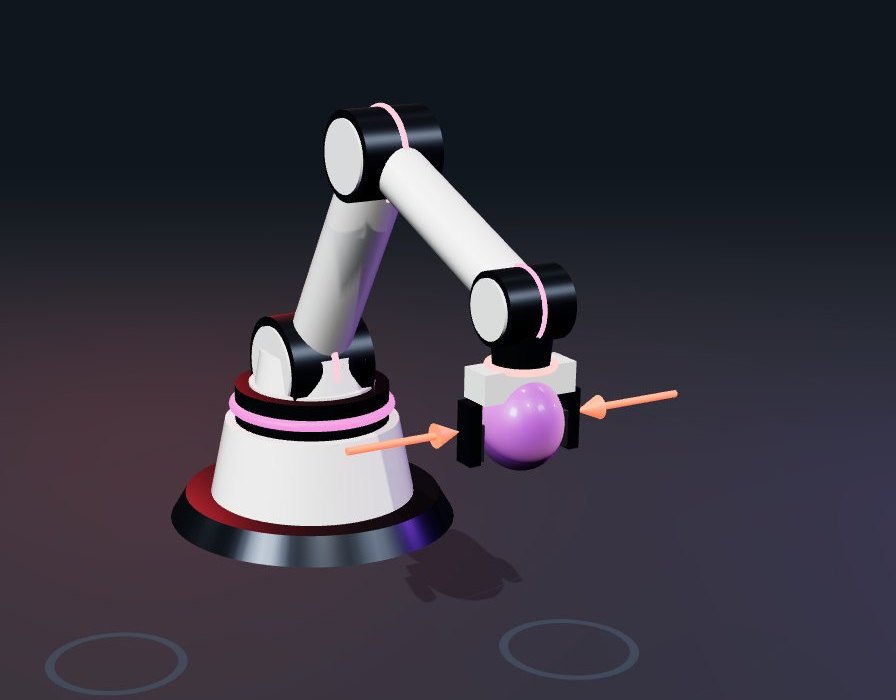
Touch sensors exist, but they are often too costly and too fragile for factory work. Enact measures force inside the robot's motors instead. It works the way you feel muscle tension in your arm, not only at your fingertips, and it needs no extra hardware bolted on.
The result is a proprioceptive nervous system: real-time awareness of every push, pull and contact across the whole body of the robot.
Why vision and language are not enough.
Camera-first robots
Most robots rely mainly on cameras. That makes it hard to handle objects reliably and to learn from physical experience, because contact, slip and resistance are invisible in pixels.
Force-aware robots
Enact pushes beyond pure vision and language approaches. Force and touch feedback lets robots learn fine manipulation more efficiently and perform tasks faster.
The whole stack, rethought together.
Dexterity does not come from one layer. Enact works across all of them at once, in one building in Zürich.
Model architectures
The cortex: models that make sense of force data and decide what the robot does next.
Built on top of existing models, such as video models, adapted to output robot actions.
Data pipelines
Physical interaction data captured from the robot's own body, every time it moves.
Feeding learning with what the robot felt, not only what it saw.
Actuators
The motors are the sensors. Load and contact are read from the drives that move each joint.
No fragile skins or add-on sensors required.
Sensors
Proprioception across the whole body, from base to fingertips.
Designed for anything from a simple arm to a full humanoid.
“We can build on top of existing models, like video models.”Manuel Yves Galliker, Founder and CEO. Previously led software for the NEO humanoid at 1X and worked at Physical Intelligence.
Have a task that needs a sense of touch?
Enact is in talks with large European companies in manufacturing, infrastructure, retail and food processing about its first deployments.